 world computeOpen playground
Intelligence, meet the world
The API to the
physical world.
Evaluate physical intelligence beyond your lab.
Your model. Real robots. A world of possibilities.
Scroll to enter the world
37° 46′ N 122° 25′ W
A FIELD GUIDE TO PHYSICAL INTELLIGENCE
A FIELD GUIDE TO PHYSICAL INTELLIGENCE
ENTERING THE EVALUATION ENVIRONMENT
01 — THE WORLD
FOREST CLAY OCEAN
BUILT FOR EXPLORATION ↓02 — The comparison
ILLUSTRATIVE PREVIEWSame task.
Different intelligence.
One task, across models and embodiments.
Explore where intelligence meets hardware.
↳ Make a quesadilla from scratch.
| ROBOT ARM ↓ AI MODEL → | AstraMODEL / 01 | OpusMODEL / 02 | Dream-1MODEL / 03 | Pi0MODEL / 04 |
|---|---|---|---|---|
| 01SO100The Robot Studio3D preview available | Illustrative motion | Illustrative motion | Illustrative motion | Illustrative motion |
| 02YAMI2RT Robotics3D model preview | 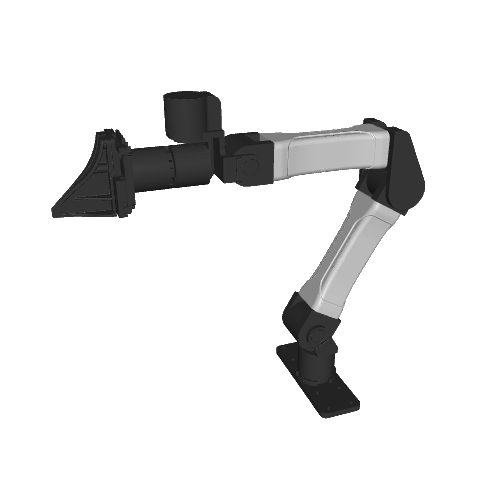 | |||
| 03Franka PandaFranka Robotics3D model preview | 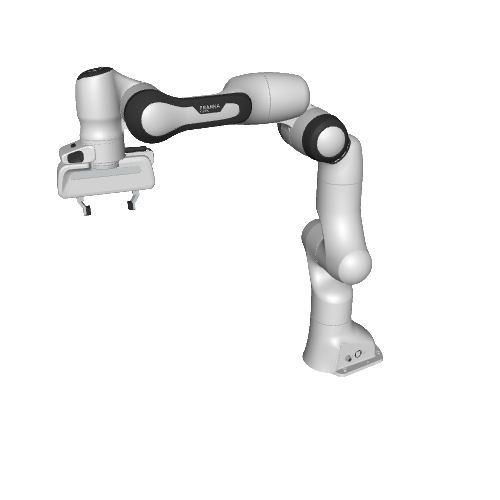 | |||
| 04WidowX 250 6DOFTrossen Robotics3D model preview | 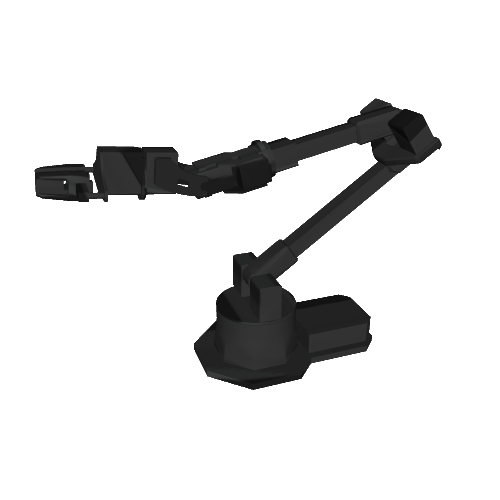 | |||
Motion previews are illustrative. Model evaluations and results are coming soon.MODEL SOURCE & LICENSE ↗
03 — The physical world
Then, let the
real world answer.
The same instruction. Physical hardware.
Follow the task from the first action to the final plate.
WORLD COMPUTE / FIELD RECORDING 001FILM COMING SOON
The quesadilla test“Make a quesadilla
“Make a quesadilla
from scratch.”
A real robot. A complete task.
The execution film is on its way.
01 PREPARE02 ASSEMBLE03 COOK04 SERVE
↗ Full execution video⌁ Action trajectories◎ Real-world outcomes
Built with the research community
Better models begin
with better questions.
Building a robotics model or a new embodiment?
Help shape the real-world evaluation network.
Growing the research networkResearch affiliations will be added after participation is confirmed.
The next task is already waiting.
The physical world.
Live.
Watch robots take on real tasks.
The experiments. The failures. The breakthroughs.
NOW STREAMING ON
Channel links coming soon.